Sep. 2023 – Jul. 2027 (expected)
I am an undergraduate in Computer Science and Technology at China University of Geosciences (Wuhan), and an incoming Ph.D. student at the School of Computer Science, Peking University, starting in Fall 2027. I currently work as a research intern in IF-Lab under the supervision of Prof. Xiang Chen.
I build efficient systems for Physical AI. My current work asks a simple question: how can vision-language-action, vision-language-navigation, and world-action models run fast enough, reliably enough, and efficiently enough for real robots? I explore speculative decoding, token caching, sparse computation, and edge-cloud collaboration from algorithm design to runtime implementation.
In the long run, I am interested in the system bottlenecks behind long-horizon reasoning, physical consistency, and closed-loop robot control. 🤝 I am always happy to discuss research and open-source collaboration in embodied AI systems, efficient inference, and related infrastructure. If our interests overlap, feel free to email me.
Conference Reviewer: AAAI 2027IJCNN 2027ICCAD 2027.


Official previews · full tracks open on the linked music platform
Sep. 2023 – Jul. 2027 (expected)
Starting Sep. 2027
School of Computer Science, Peking University
Incoming Ph.D. Student in Computer Science
Advisor: Prof. Xiang Chen
Oct. 2025 – Present Research Intern @ IF-Lab, Peking University
Advisor: Prof. Xiang Chen
Efficient VLA/VLN inference, token caching, speculative decoding, and systems optimization for embodied AI.
Feb. 2025 – Sep. 2025 Undergraduate Researcher @ China University of Geosciences (Wuhan)
Algorithm and data analysis for an intelligent Coriolis-force experiment platform.
Nov. 2024 – May 2025 Undergraduate Researcher @ China University of Geosciences (Wuhan)
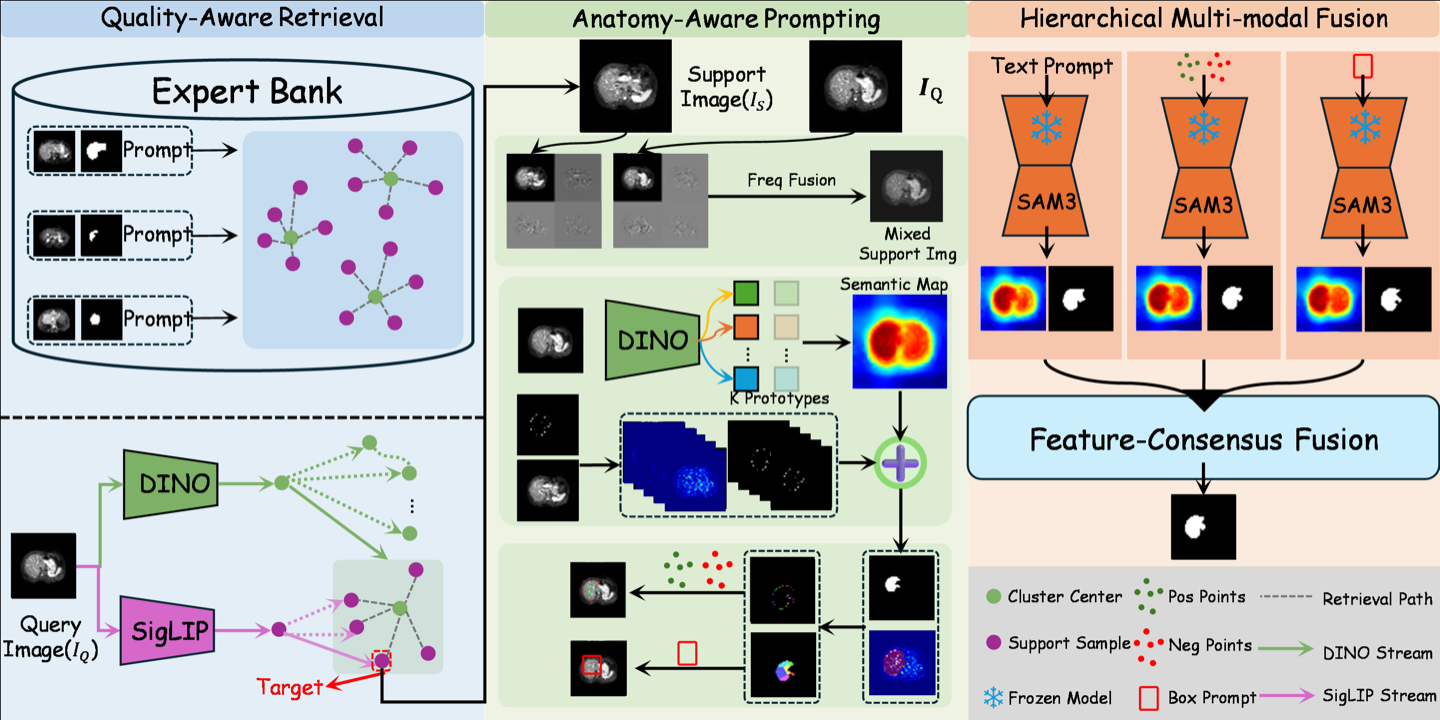
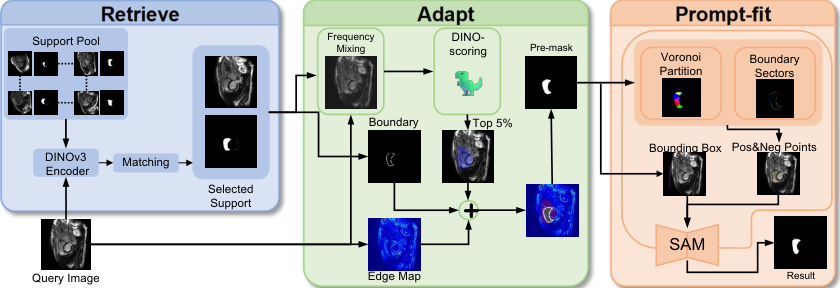
Training-free few-shot medical image segmentation.
Aug. 2026
I will join the School of Computer Science at Peking University as a Ph.D. student in Fall 2027.
2026
KERV was accepted by DAC 2026.
2026
APEX-SAM was accepted by MICCAI 2026.
2026
RAP was accepted by IJCNN 2026.
Jul. 2026
Our differential-evolution poster paper was published in the GECCO 2026 Companion.
2026
Excellent Poster Paper Award, FJSP-DUET
2024–2025
BYD Scholarship · Scholarship Support
China University of Geosciences (Wuhan)
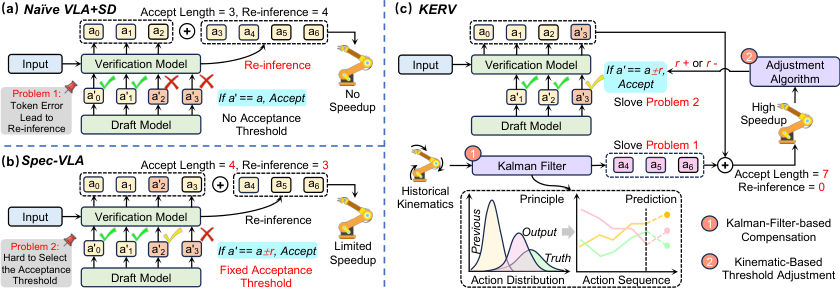
KERV: Kinematic-Rectified Speculative Decoding for Embodied VLA Models
DAC 2026, accepted / to appear
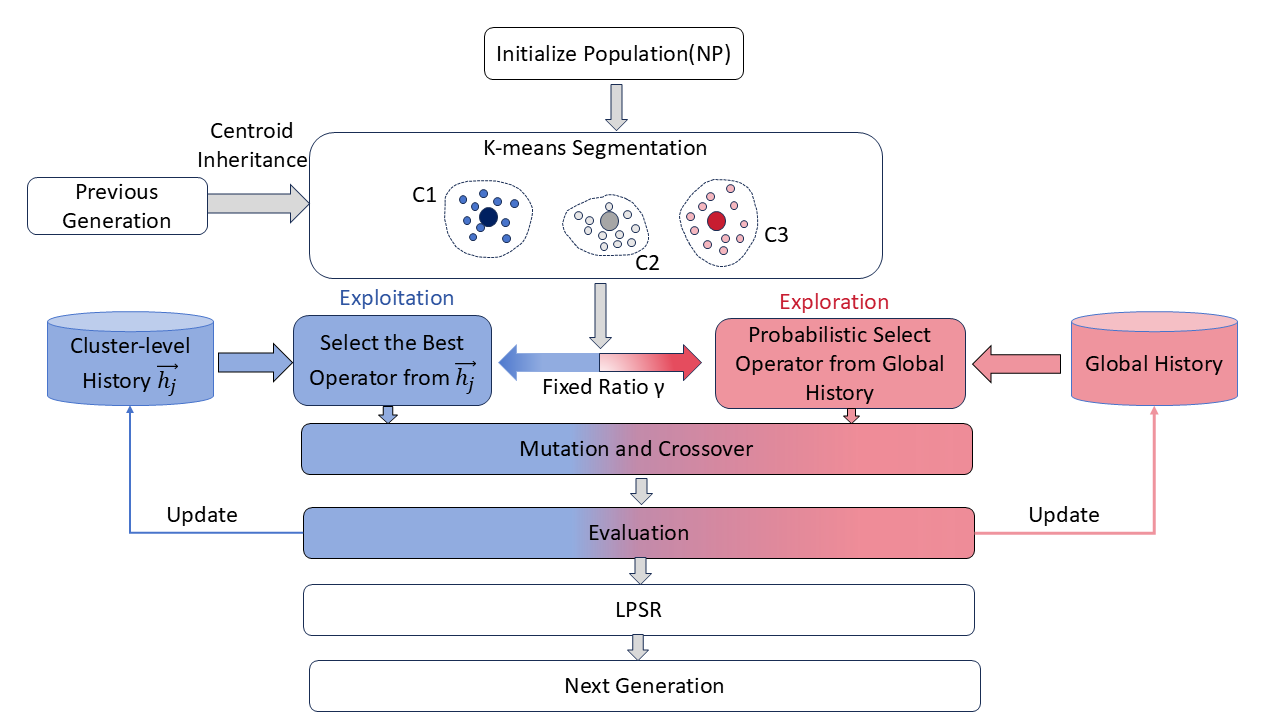
A Clustering Aided Multi-Operator Differential Evolution via Cluster-Level Adaptation
GECCO 2026 Companion, pp. 349–352 (Poster Paper)
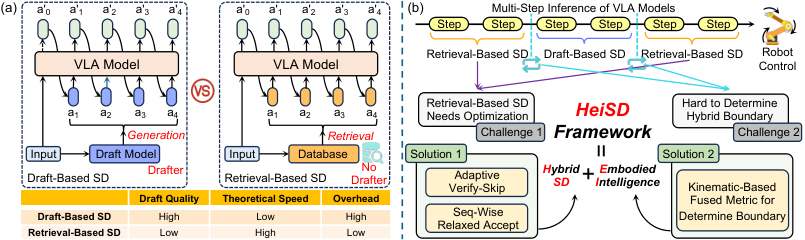
arXiv preprint arXiv:2603.17573
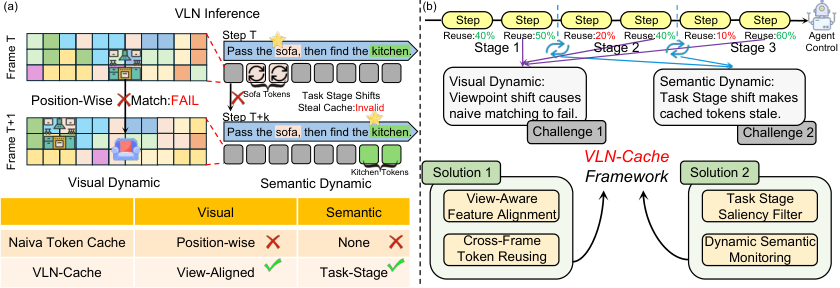
VLN-Cache: Enabling Token Caching for VLN Models with Visual/Semantic Dynamics Awareness
arXiv preprint arXiv:2603.07080
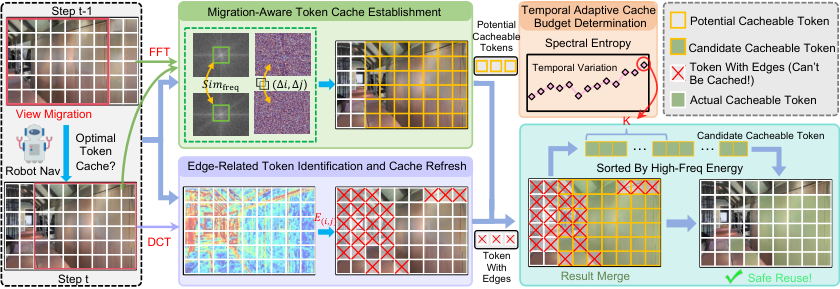
FreqCache: Accelerating Embodied VLN Models with Adaptive Frequency-Guided Token Caching
arXiv preprint arXiv:2604.24391
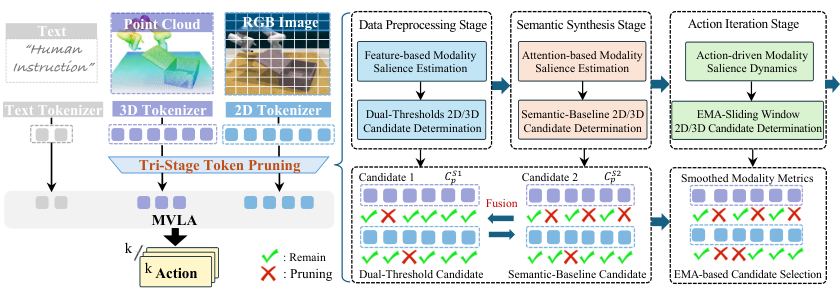
arXiv preprint arXiv:2604.09244
To be added after public verification.
KERV Core Contributor
Core contributor to the open-source implementation of kinematic-rectified speculative decoding for embodied VLA models, including project presentation, figure cleanup, and contributor metadata.

RoboECC Core Contributor
Core contributor to the open-source edge-cloud collaborative deployment framework for VLA models, covering multi-factor-aware partitioning and online deployment adjustment.
[Paper]

A-Pilot: Quantized Edge Deployment for MoE Models Contributor
Contributor to a reproducible MiniCPM-MoE 8×2B deployment on NVIDIA Jetson AGX Orin, with mixed-precision quantization, a C++/CUDA runtime, performance benchmarking, and model-quality evaluation.

CUG Template Creator & Maintainer
Creator and maintainer of an unofficial template collection for China University of Geosciences (Wuhan), covering PowerPoint, Beamer, Word, and LaTeX reports and thesis defenses.

RoboNix Ecosystem Core Contributor
Core contributor to the embodied AI operating system, with four merged upstream pull requests covering unchanged-scene VLM inference reuse and service publication in the RoboNix package catalog.

Experience Memory and Reuse Skill RoboNix Skill
Experience-memory retrieval and verified action reuse for OpenVLA and π0, with policy fallback for safe online execution.

Motion-Aware Action Verification and Recovery Skill RoboNix Skill
Motion-aware candidate verification, compensation, and policy recovery for speculative VLA execution.

Memory Action Retrieval Service RoboNix Service
A deployable, provenance-aware service that turns embodied execution history into reusable candidate action trajectories.

VLA Action Verification Service RoboNix Service
A deployable action-decision service with speculative decoding, verification, and deterministic fallback.

2026
Meritorious Winner, Mathematical Contest in Modeling
2025
First Prize, National University Physics Experiment Competition
2025
Bronze Medal, ICPC Asia Nanjing Regional Contest
2025
Bronze Medal, ICPC Asia Chengdu Regional Contest
2025
National Second Prize, RoboCup China, Advanced Robot Vision 3D Recognition
2025
National Team Second Prize, Group Programming Ladder Tournament
2025
First Prize, Hubei Mathematical Contest in Modeling
2024
National First Prize, RAICom, Machine Vision System Innovation
2024
National Third Prize, Lanqiao Cup C/C++ Programming, University Group A